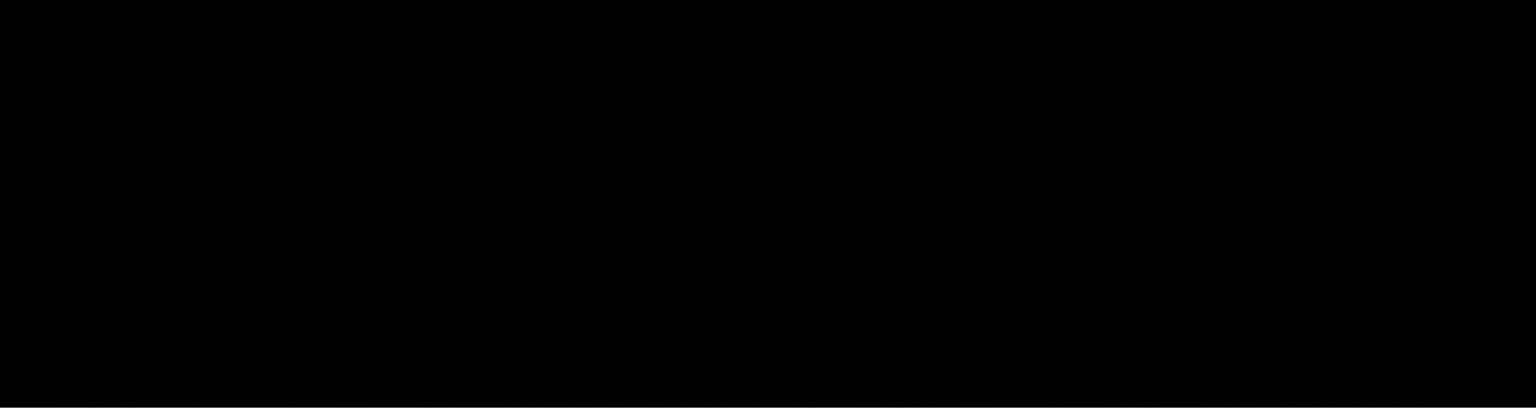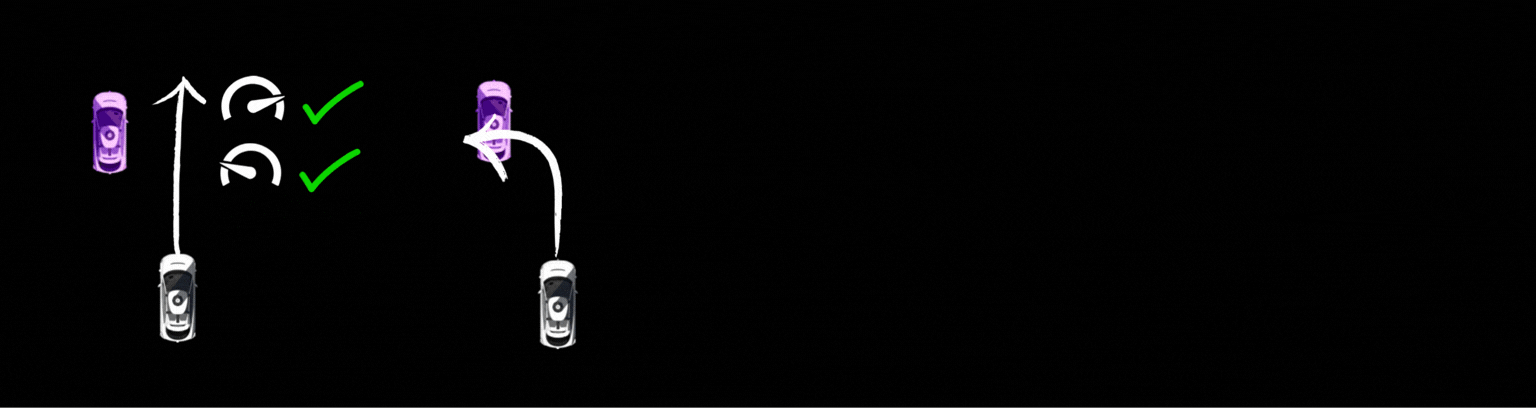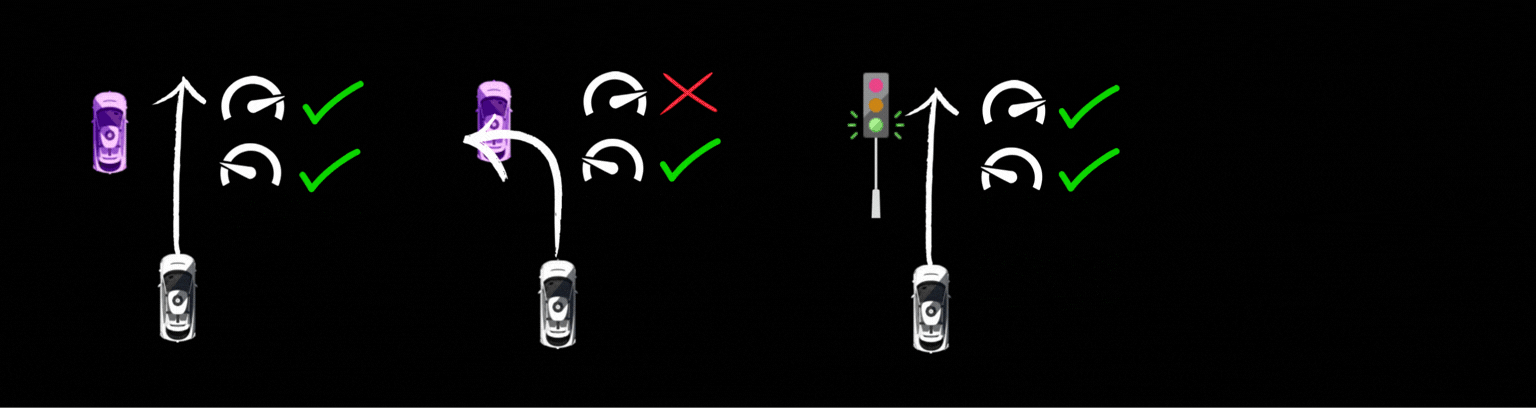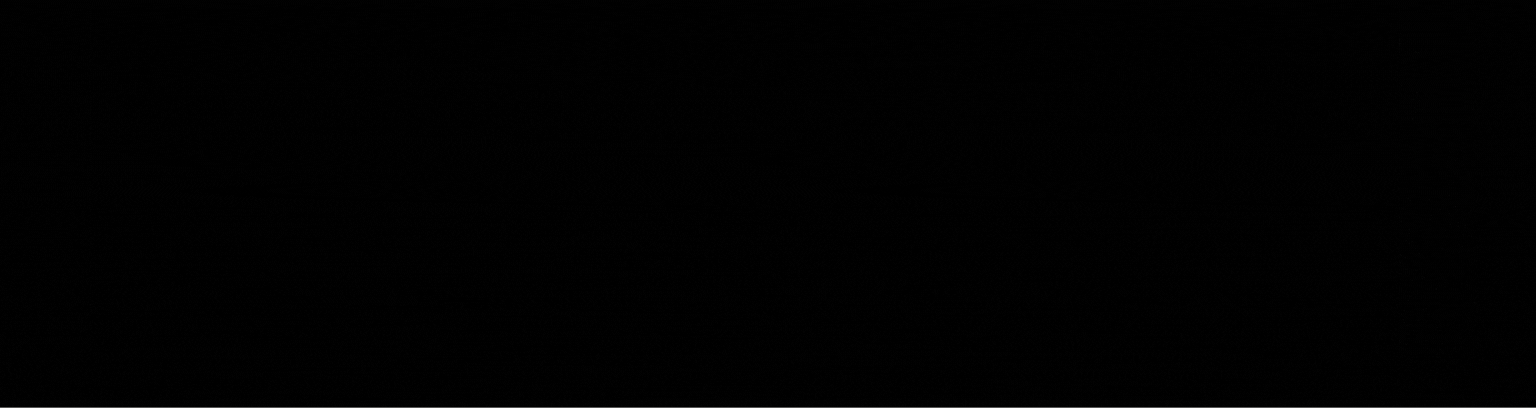
CLAP-AD separates path imitation from speed selection. It predicts a driving path, evaluates candidate speeds against safety criteria, and selects a speed that follows the user's request whenever it is safe.
WACV 2027
CLAP-AD separates path imitation from speed selection. It predicts a driving path, evaluates candidate speeds against safety criteria, and selects a speed that follows the user's request whenever it is safe.
End-to-end autonomous driving is commonly trained by imitating a single expert behavior per scenario. This makes it difficult to learn alternative valid behaviors and leaves models vulnerable to noisy or ambiguous speed labels. We introduce Closed-Loop Aware Planning for Autonomous Driving (CLAP-AD), a plug-in planning head that separates path prediction from speed selection: it learns the path through imitation, then scores candidate speeds using multiple safety criteria grounded in physical constraints. At test time, a user can specify a desired speed, which the planner follows when feasible while falling back to safe alternatives as needed—without retraining. On Bench2Drive-Speed, CLAP-AD achieves a Speed-Adherence score of 82.53, exceeding the strongest baseline by 12.9 points. On Bench2Drive it improves the driving scores of UniAD and VAD by 28.5 and 32.7 points, respectively, while retaining strong performance with TFv6. On NAVSIM v2, it improves its LTFv6 backbone's EPDMS by 6.1.
CLAP-AD first predicts a feasible path from the scene representation provided by an existing end-to-end driving model. Dedicated scoring heads then evaluate candidate speeds along that path for collision risk, traffic-light compliance, and stop-sign compliance. At deployment, speed classes that pass the safety threshold are feasible; a selector can choose the feasible speed closest to a requested target, or use another policy such as the median for cautious driving. This planning head integrates with different backbones, including UniAD, VAD, and TFv6.
The path planner and criterion-specific speed-scoring heads work together to choose a safe, controllable speed.
Closed-loop showcase of the planner adapting its speed to traffic and safety constraints. CLAP-AD planner using a VAD backbone on CARLA routes.
Results on 48 routes. Speed-Adherence (SA) measures how closely the vehicle follows the requested speed. CLAP-AD improves adherence on all three backbones.
| Method | SA (All) ↑ | Easy ↑ | Medium ↑ | Hard ↑ | Efficiency ↑ | Driving Score ↑ | Success Rate ↑ |
|---|---|---|---|---|---|---|---|
| TCP-Speed | 69.23 | 76.18 | 68.71 | 62.81 | 169.84 | 29.66 | 18.75 |
| SparseDriveV2 | 51.13 | 52.50 | 49.72 | 51.18 | 91.77 | 94.63 | 60.41 |
| UniAD | 54.22 | 56.14 | 52.62 | 53.90 | 108.49 | 18.90 | 4.16 |
| UniAD + CLAP-AD | 79.41 (+25.2) | 83.83 | 75.40 | 79.00 | 170.03 | 75.15 | 41.67 |
| VAD | 61.63 | 64.64 | 62.60 | 57.66 | 130.53 | 40.23 | 20.83 |
| VAD + CLAP-AD | 75.51 (+13.9) | 80.42 | 72.05 | 74.07 | 159.48 | 90.52 | 52.08 |
| TFv6 | 69.64 | 70.75 | 68.30 | 69.86 | 154.58 | 92.59 | 58.33 |
| TFv6 + CLAP-AD | 82.53 (+12.9) | 89.79 | 76.81 | 80.98 | 187.80 | 88.47 | 50.00 |
SA is reported for all routes and the Easy, Medium, and Hard splits. CLAP-AD's TFv6 variant attains the best overall Speed-Adherence, trading 4.1 Driving Score points against the TFv6 baseline.
Results on the 220 Bench2Drive routes. Each CLAP-AD variant replaces the planning head of its corresponding backbone; the driving-score difference is relative to that backbone.
| Method | Test-time speed control | Driving Score ↑ | Δ Score | Success Rate (%) ↑ |
|---|---|---|---|---|
| UniAD | No | 45.81 | — | 16.36 |
| UniAD + CLAP-AD | Yes | 74.29 | +28.5 | 49.09 |
| VAD | No | 42.35 | — | 15.00 |
| VAD + CLAP-AD | Yes | 75.04 | +32.7 | 47.27 |
| TFv6 | No | 94.70 | — | 82.10 |
| TFv6 + CLAP-AD | Yes | 92.30 | −2.4 | 75.00 |